I am a PhD student in Control Science and Engineering at Shanghai Jiao Tong University (SJTU), supervised by Prof. Yue Gao. Currently, I am conducting researches on Embodied AI at Shanghai Innovation Institute and MoE key lab of Artificial Intelligence. Previously, I received my bachelor’s degree in Measurement and Control Technology from Jilin University.
My research interest includes: Vision-Language-Action (VLA), World Model, RL Post-training, Robust Whole-body control for humanoid robots;
I am a final-year PhD candidate at SJTU, expected to graduate in June 2027. Currently, I am actively seeking research internships or jobs about Embodied AI.
📝 Publications
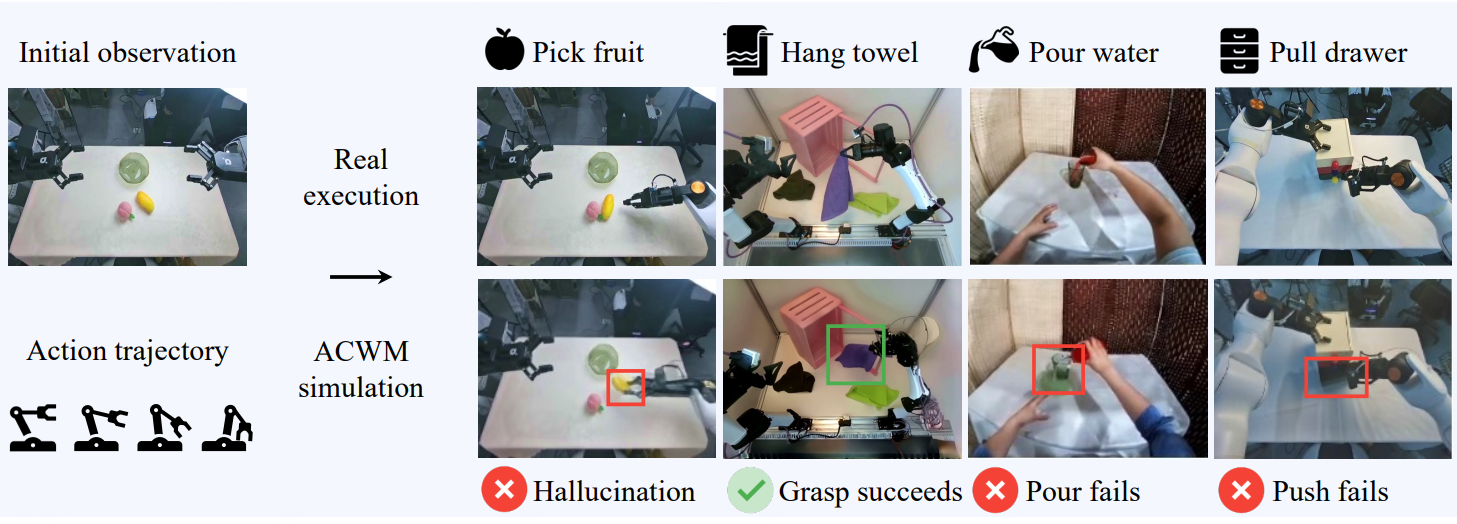
WorldOracle: Benchmarking Action-Conditioned World Models against Real-World Executions
Haoyi Duan, Liliang Chen, Nan Wang, Yang Zhang. Paper
- Benchmark action-conditioned world models against real-world executions under identical initial observations and action sequences.
- Curate long-horizon trajectories across three embodiments, including successful and failed interactions.
- Evaluate physical correctness, spatial alignment, interaction-region fidelity, and multi-view action coherence.
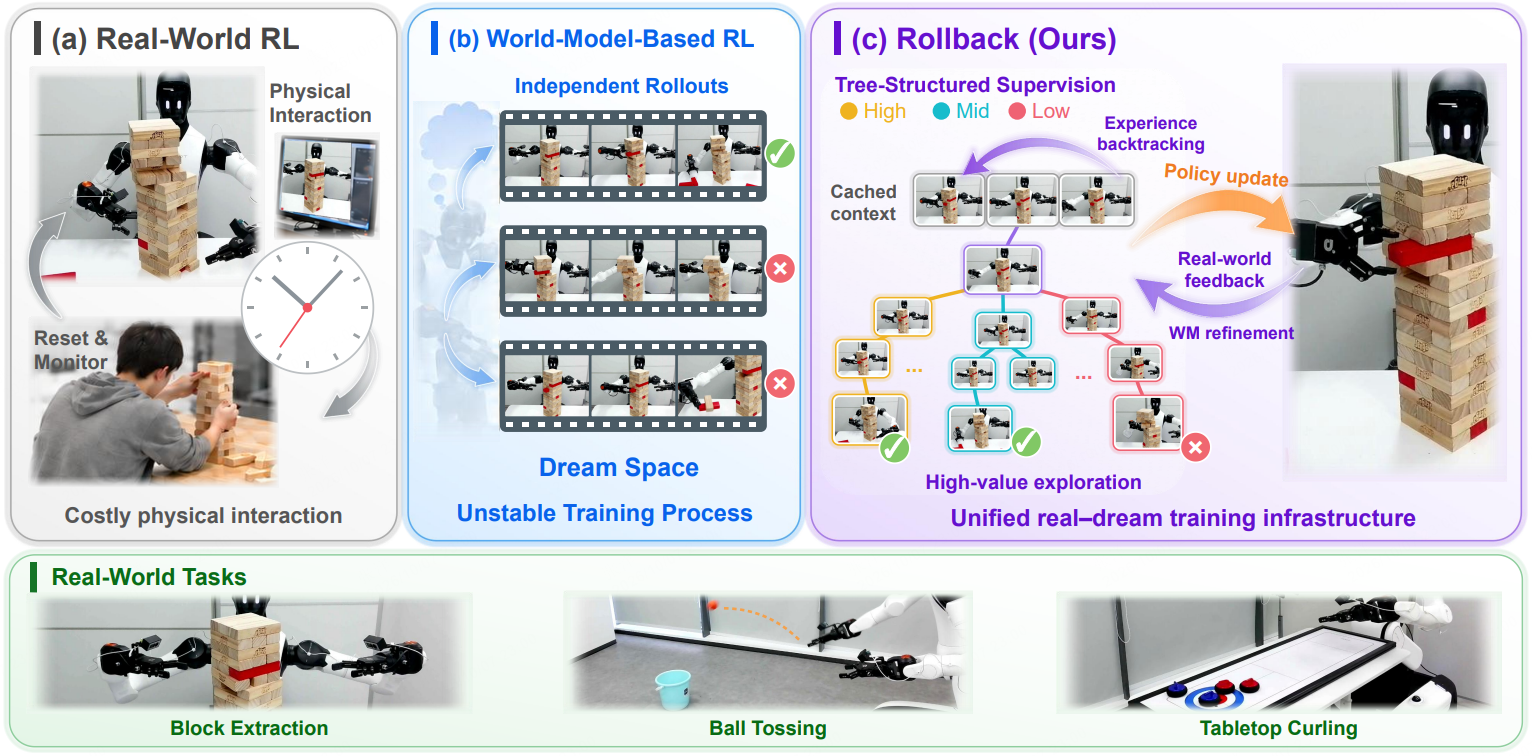
Rollback: Experience Backtracking in World Models for Policy improvement
Jiayi Luo, Yang Zhang. Paper
- Revisit critical decisions through experience-backtracking tree search in world models.
- Derive action-level supervision from counterfactual outcomes without a learned value model.
- Achieve higher real-robot success rates and more stable policy improvement.
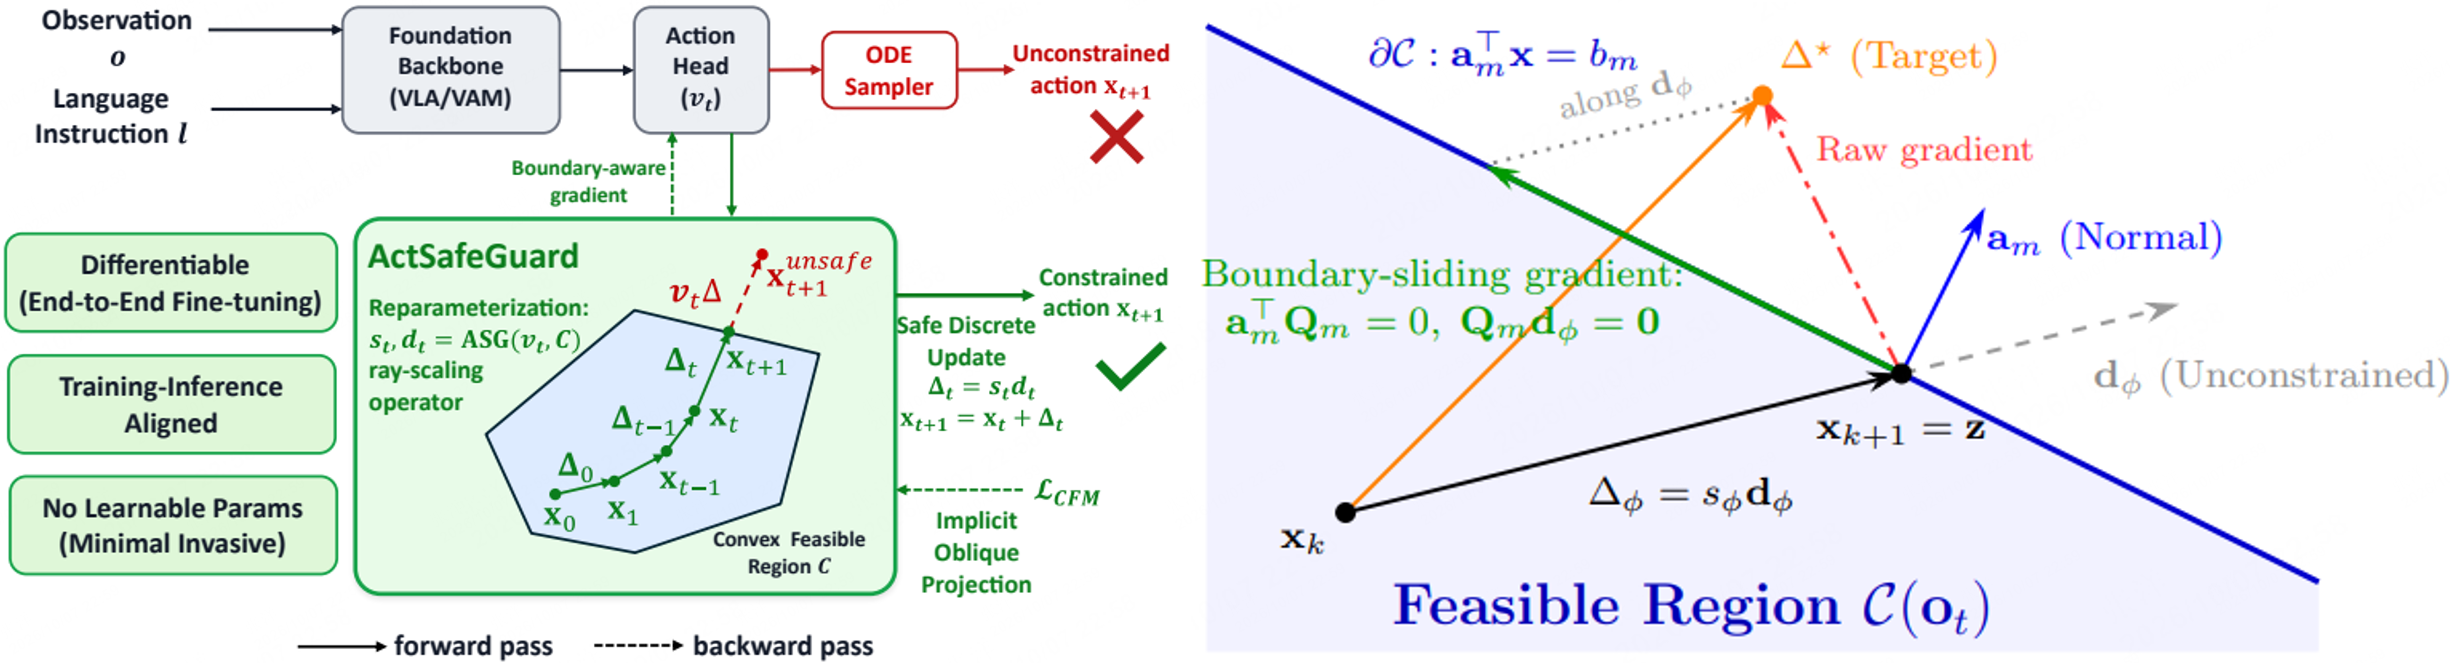
ActSafeGuard: Differentiable and Training-Aligned Constraint Enforcement for Flow-Matching Policies
Jianming Ma, Rongjun Jin, Xiaxi Si, Yang Zhang, Yue Gao. Paper
- Enforce hard action constraints during policy training and inference.
- Enable boundary-aware learning through differentiable ray scaling.
- Achieve 100% step safety with competitive task success.
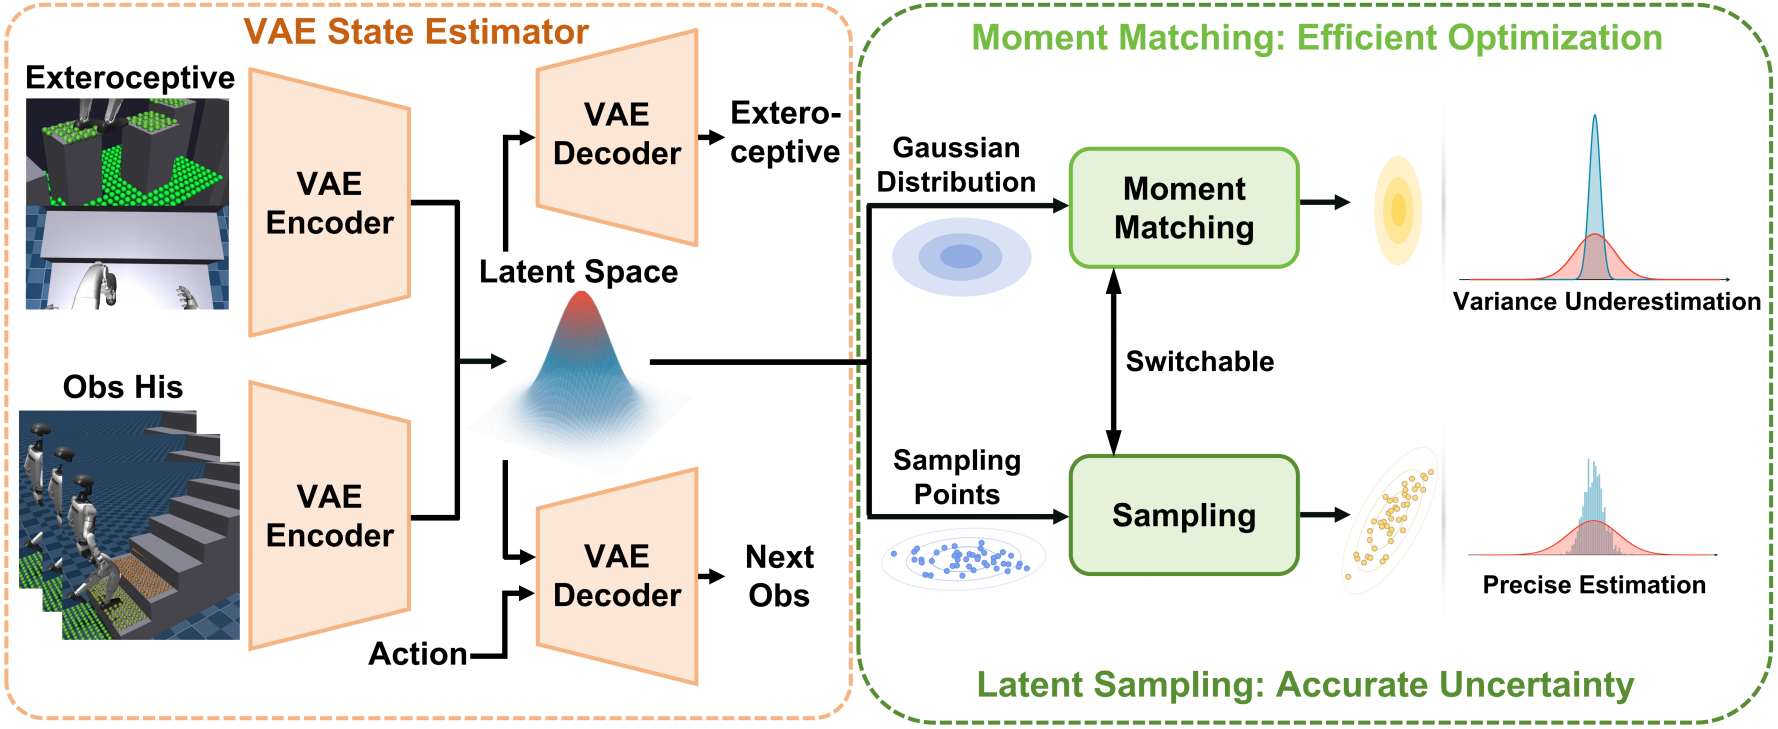
P3: Probabilistic Policy Propagation for Stable VAE-Based Robot Learning
Liyun Yan, Jianming Ma, Yang Zhang, Shengcheng Fu, Yue Gao. Paper
- Propose distribution-aware PPO for stable VAE-based robot learning.
- Combine moment matching with sampling-based calibration under latent uncertainty.
- Improve data efficiency and accelerate convergence in humanoid parkour.
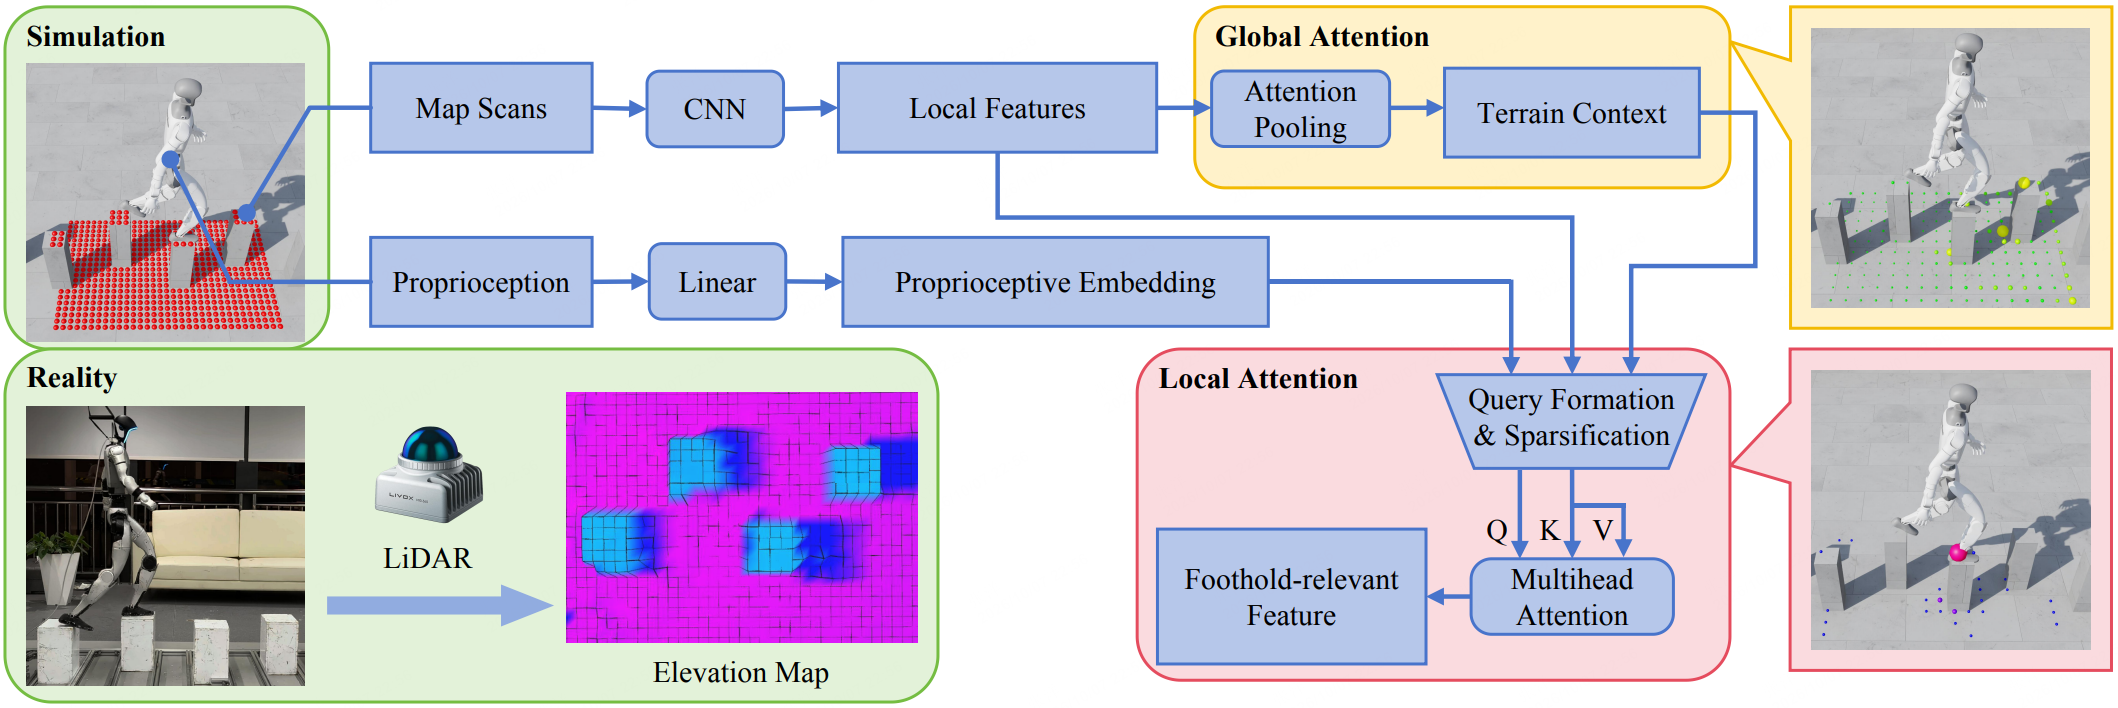
Global-Local Attention Decomposition for Terrain Encoding in Humanoid Perceptive Locomotion
Shengcheng Fu, Yang Zhang, Zhanxiang Cao, Liyun Yan, Yue Gao. Paper
- Decompose terrain attention into global context and local foothold geometry.
- Enable precise foothold selection and emergent terrain-aware navigation.
- Achieve zero-shot sim-to-real transfer using onboard LiDAR.
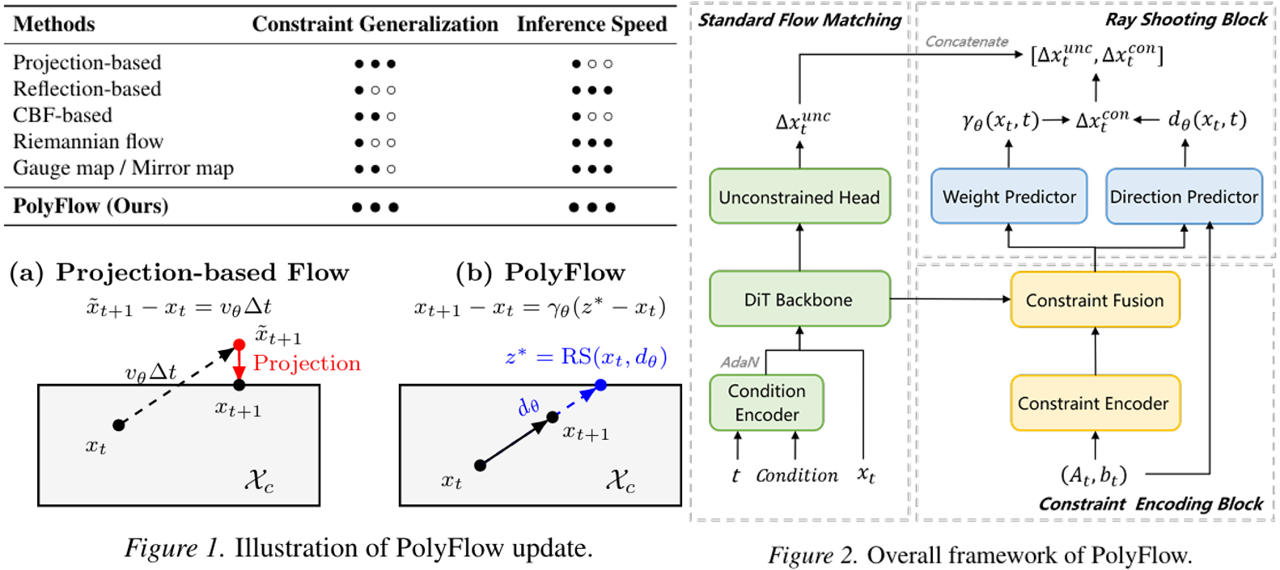
Jianming Ma, Qiyue Yang, Yang Zhang, Liyun Yan, Zhanxiang Cao, Yazhou Zhang, Yue Gao. Paper
- Discrete-time flow matching with guaranteed zero constraint violation.
- Projection-free update via differentiable ray shooting boosts efficiency.
- Favorable trade-off across safety, fidelity and inference speed.
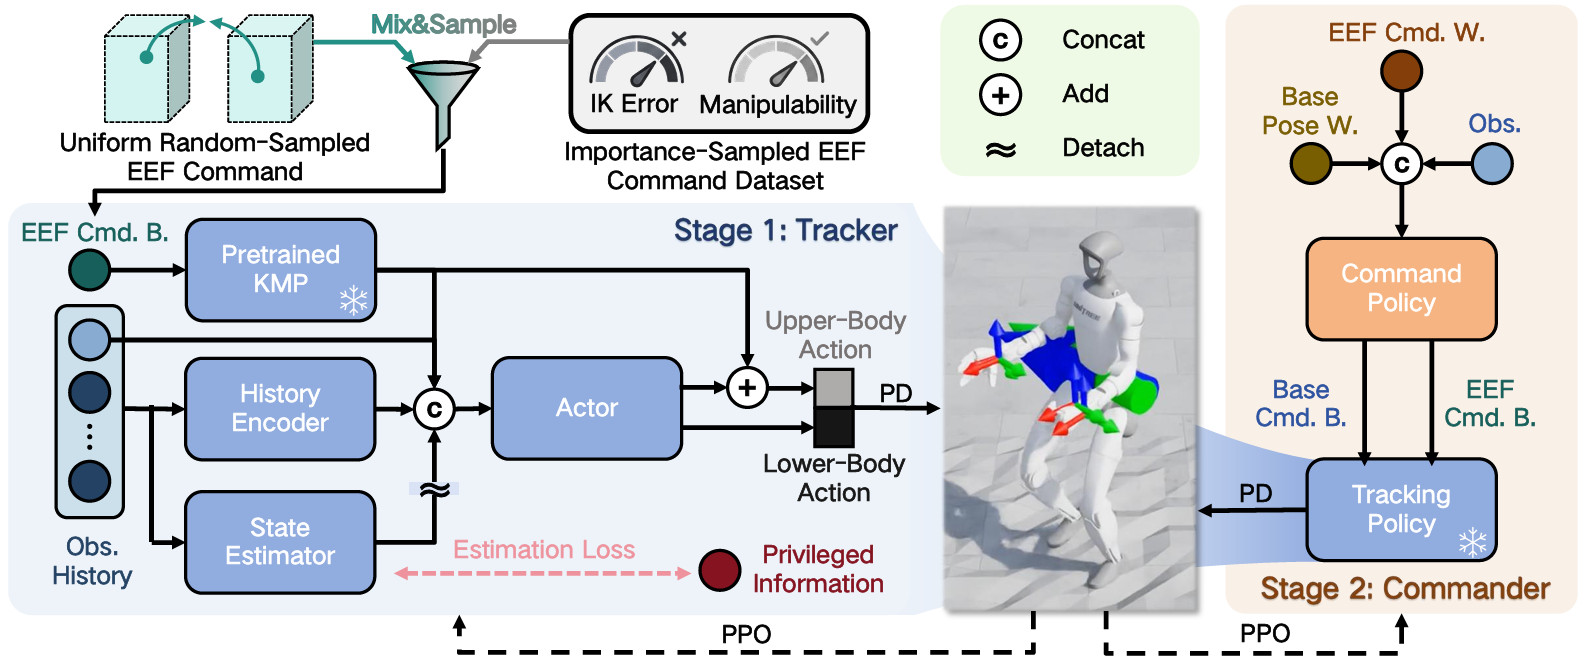
HiWET: Hierarchical World-Frame End-Effector Tracking for Long-Horizon Humanoid Loco-Manipulation
Zhanxiang Cao, Liyun Yan, Yang Zhang, Sirui Chen, Jianming Ma, Tianyue Zhan, Shengcheng Fu, Yufei Jia, Cewu Lu, Yue Gao. Paper
- HiWET enhances global end-effector tracking accuracy.
- KMP improves manipulation manifold consistency.
- Enhancing loco-manipulation performance in real humanoid robots.
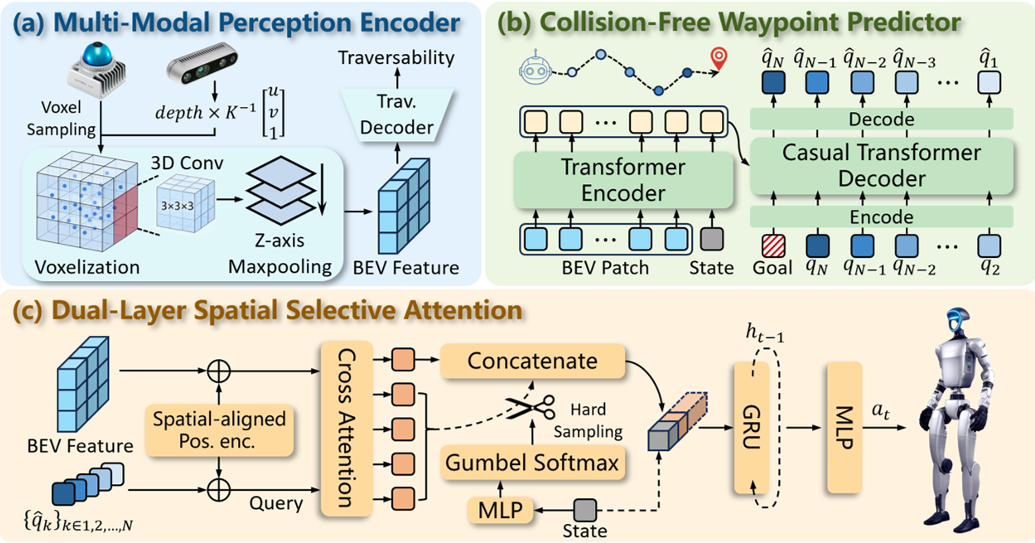
FocusNav: Spatial Selective Attention with Waypoint Guidance for Humanoid Local Navigation
Yang Zhang, Jianming Ma, Liyun Yan, Zhanxiang Cao, and Yue Gao. Paper
- Propose spatial selective attention navigation framework.
- Design waypoint-guided and stability-aware modules.
- Improve humanoid robot navigation robustness.
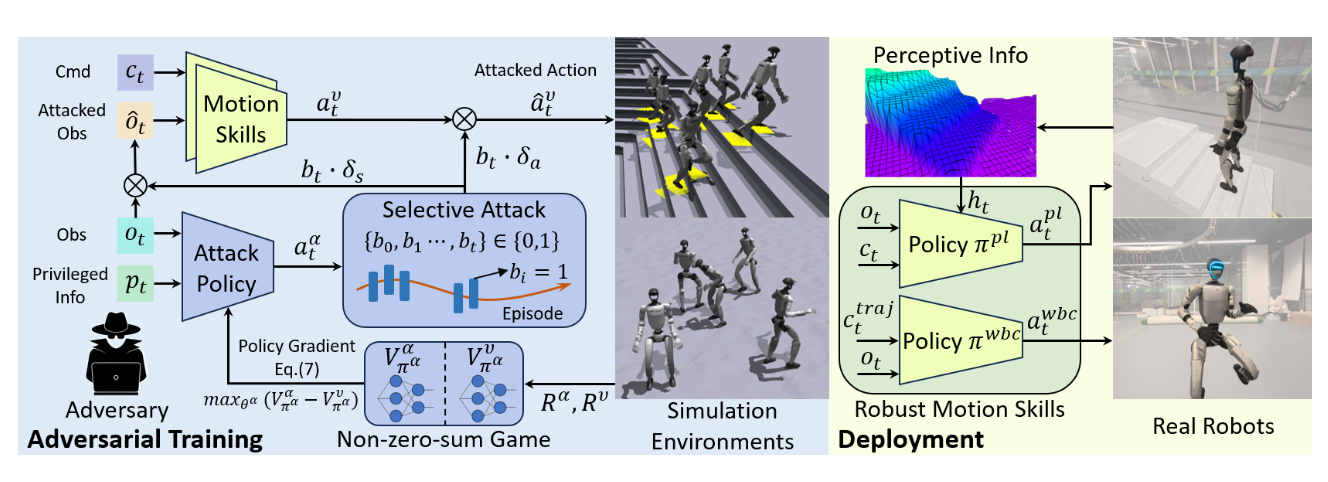
Keep on Going: Learning Robust Humanoid Motion Skills via Selective Adversarial Training
Yang Zhang, Zhanxiang Cao, Buqing Nie, Haoyang Li, Zhong Jiangwei, Qiao Sun, Xiaoyi Hu, Xiaokang Yang, Yue Gao. Paper
- Selective adversarial attack for the humanoid robot.
- Identify vulnerability and improve robustness.
- Improve long horizon mobility and tracking performance on real robot.
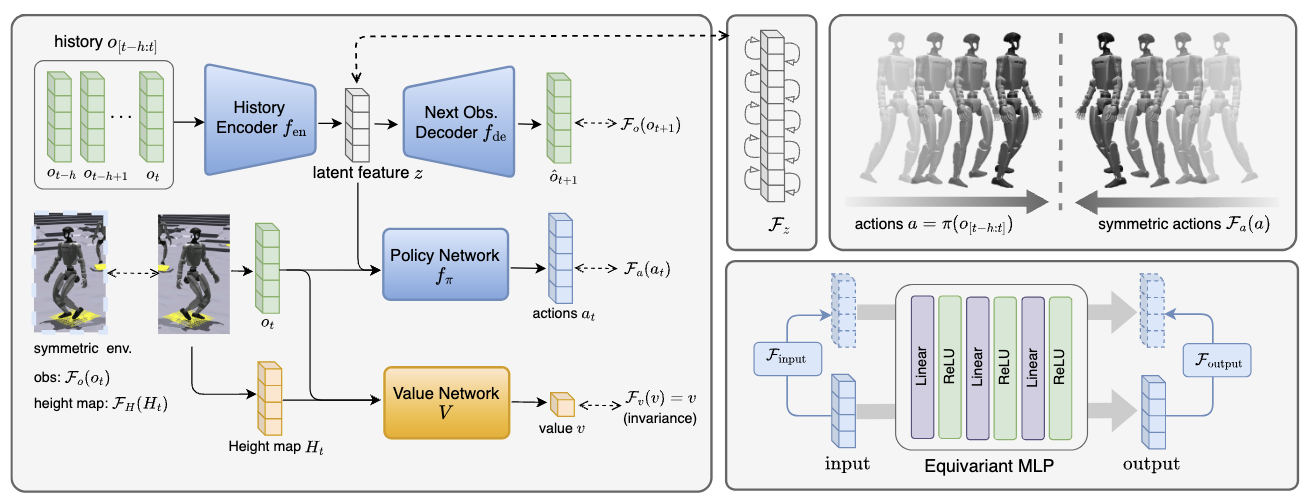
Coordinated Humanoid Robot Locomotion with Symmetry Equivariant Reinforcement Learning Policy
Buqing Nie, Yang Zhang, Rongjun Jin, Zhanxiang Cao, Huangxuan Lin, Xiaokang Yang, Yue Gao. Paper
- DRL-based humanoid robot policy with strict symmetry equivariance.
- Simple to implement without additional hyper-parameters.
- Higher tracking accuracy with coordinated motions.
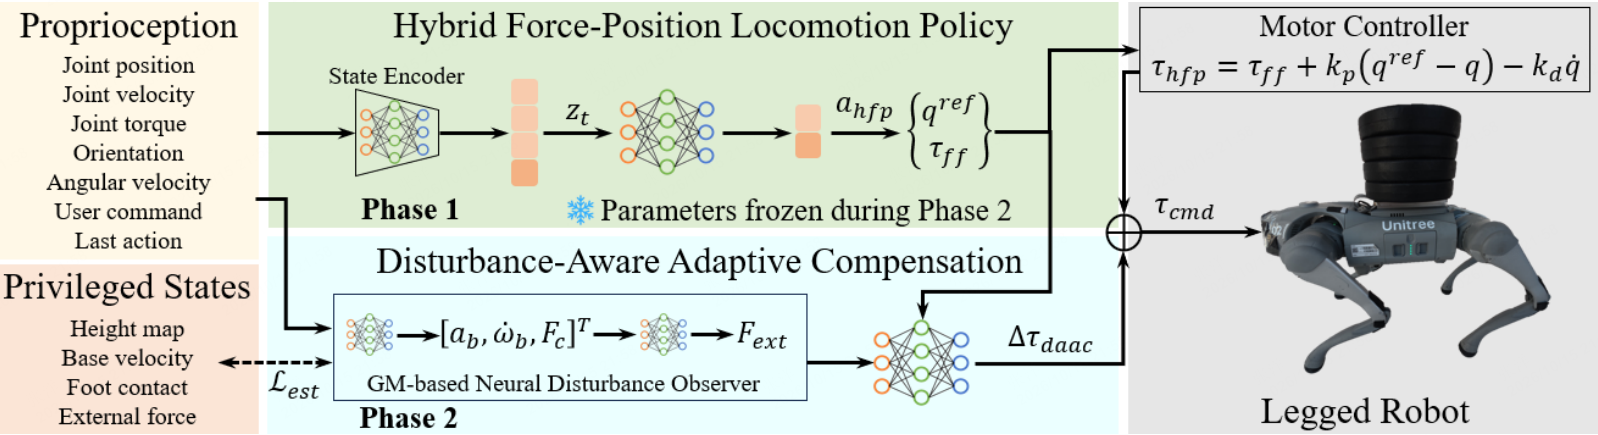
Disturbance-Aware Adaptive Compensation in Hybrid Force-Position Locomotion Policy for Legged Robots
Yang Zhang, Buqing Nie, Zhanxiang Cao, Yangqing Fu, Yue Gao. Paper
- Combine target joint positions and feedforward torques for robust legged locomotion.
- Estimate external disturbances and generate adaptive compensation torques.
- Enable a real quadruped to carry 20 kg payloads and recover more effectively from external impacts.
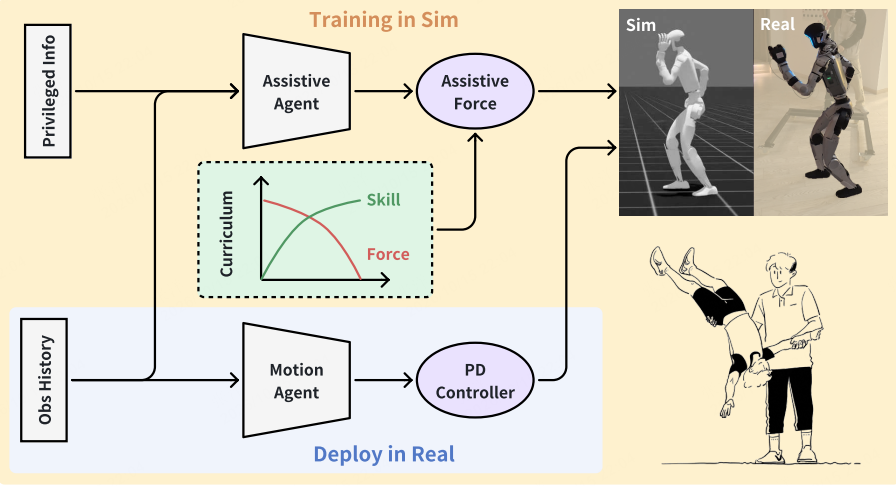
Learning Motion Skills with Adaptive Assistive Curriculum Force in Humanoid Robots
Zhanxiang Cao, Yang Zhang, Buqing Nie, Huangxuan Lin, Haoyang Li, Yue Gao. Paper
- Jointly train motion and assistive-force agents to accelerate humanoid skill learning.
- Gradually remove assistance through an adaptive force curriculum and random masking.
- Enable faster learning and deploy walking and dancing policies on real humanoids without external support.
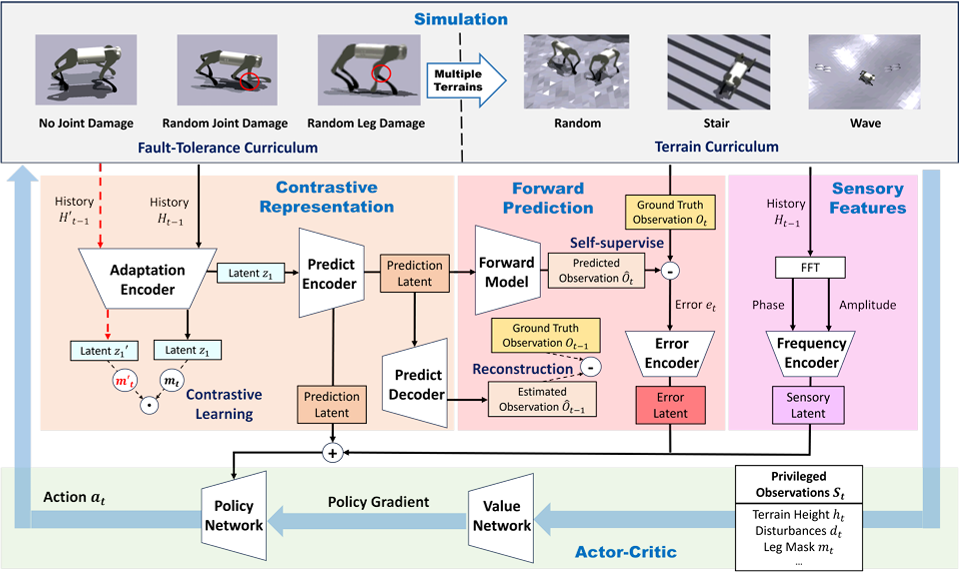
Contrastive Forward Prediction Reinforcement Learning for Adaptive Fault-Tolerant Legged Robots
Yangqing Fu, Yang Zhang, Qiyue Yang, Liyun Yan, Zhanxiang Cao, Yue Gao. Paper
- Propose contrastive forward prediction RL framework.
- Enhance legged robot fault tolerance via error feedback.
- Achieve zero-shot adaptation to unseen joint damages.
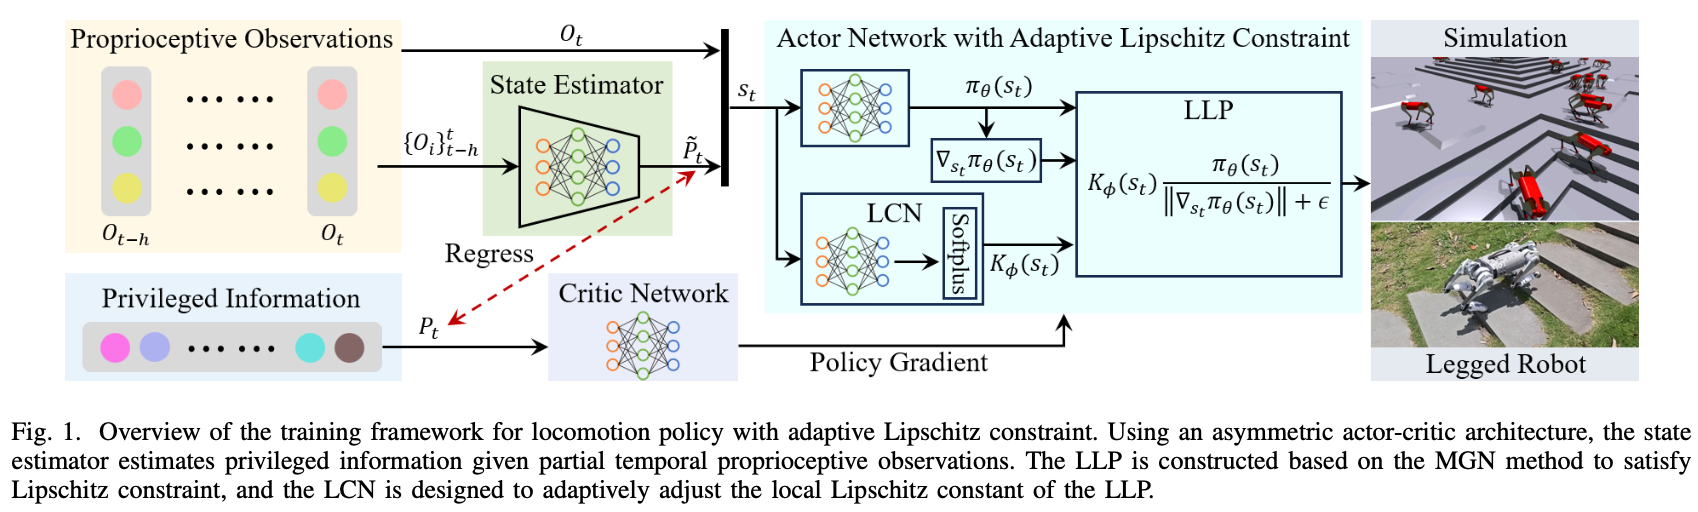
Robust Locomotion Policy with Adaptive Lipschitz Constraint for Legged Robots
Yang Zhang, Buqing Nie, and Yue Gao. Paper
- Induce adaptive Lipschitz constraint for quadruped locomotion tasks.
- Action smooth, lower energy cost, robust to obs. noise and disturbances.
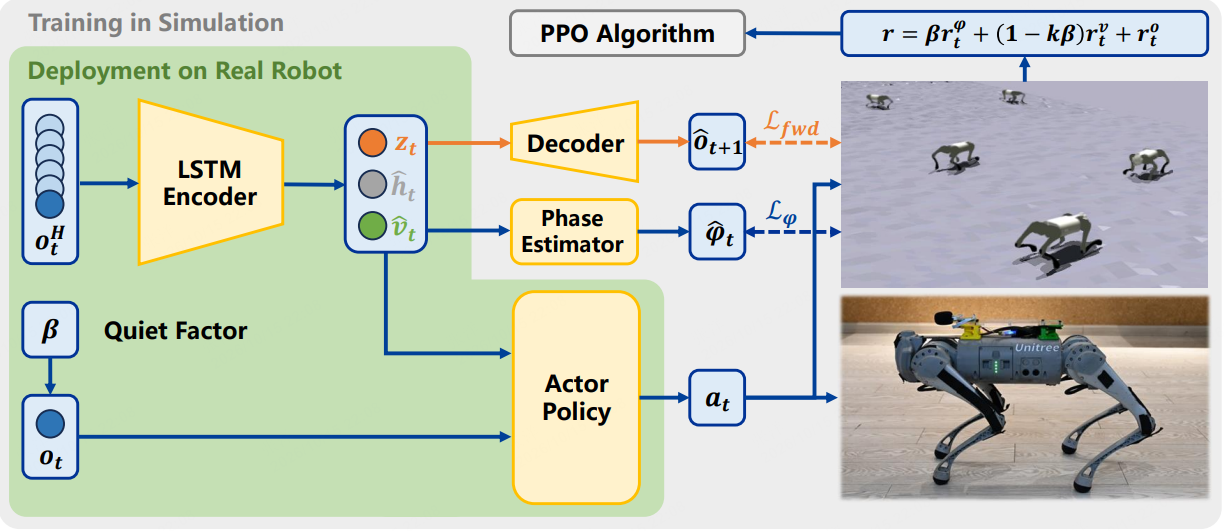
Minimizing Acoustic Noise: Enhancing Quiet Locomotion for Quadruped Robots in Indoor Applications
Zhanxiang Cao, Buqing Nie, Yang Zhang, Yue Gao. Paper
- Reduce foot-ground impact noise through phase-aware gait optimization.
- Introduce a tunable quiet factor to balance noise reduction and locomotion speed.
- Achieve approximately 8 dBA noise reduction on a real quadruped across indoor surfaces.
RCAR 2024Learning Capability to Enhance Locomotion Control and Planning for Legged Robots, Yue Gao, Changda Tian, Yang Zhang.ROBIO 2022Parameters identification of whole body dynamics for hexapod robot, Yang Zhang, Yue Gao, Ming Sun.
📖 Educations
- 2022.09 - 2027.06, PhD Candidate, Control Science and Engineering, School of Automation and Perception, Shanghai Jiao Tong University.
- 2018.09 - 2022.06, Bachelor, Measurement and Control Technology (Honor class), School of Instrument Science and Electrical Engineering, Jilin University.
💻 Academic Services
- I serve as a reviewer for AI/robotics conferences/journals, including ICLR, AAAI, ICRA, IROS, RA-L, etc.
🎖 Honors and Awards
- 2019-2021 Awarded the National Scholarship